
• 12 joints full-to-free design to support high-speed moves such as running, climbing, and back-to-air flips • 9 axes of IMU gyroscope + dynamic pace algorithms to recover from a fall and adapt to a complex terrain • 0.0. 1 mm STM32 Real-time motion control, response delay <5ms >...
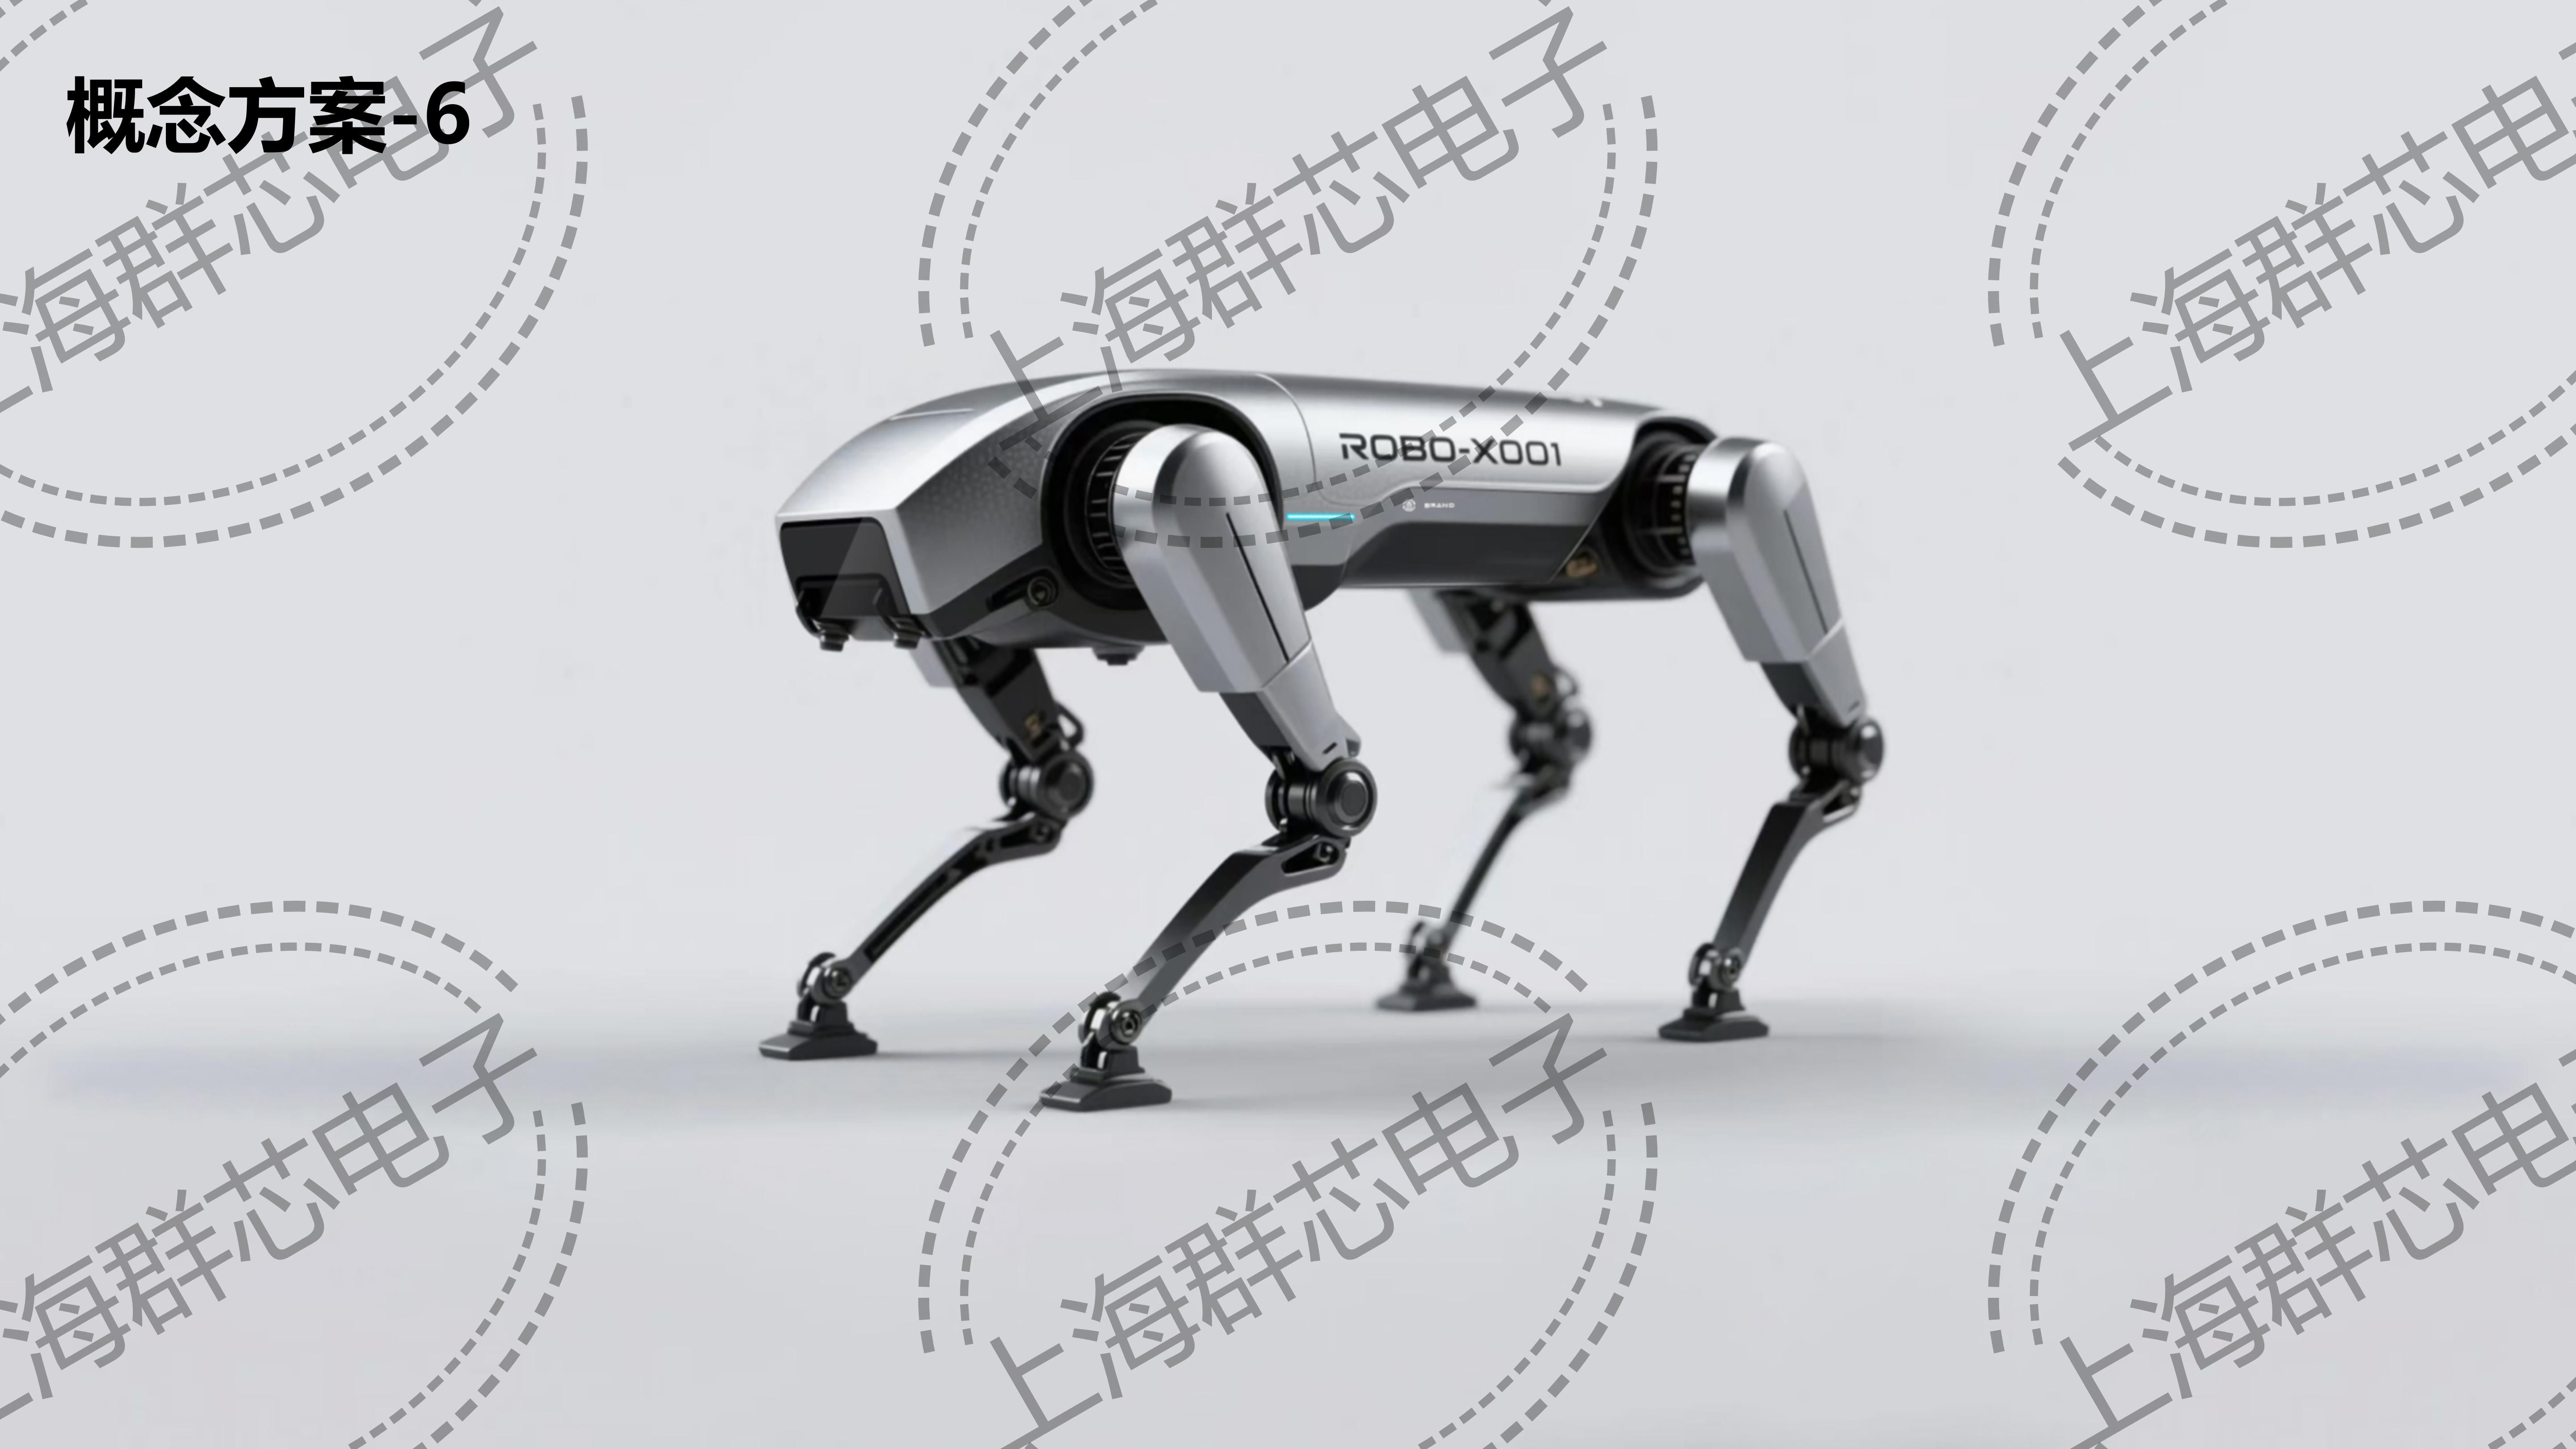
The 12-degree free-living machine dog of the "Call" series -- a new era of intelligent robots.
Subtitle:
Berry pie + STM32 Double Nuclear Architecture | High Accuracy Movement Control | Open Source Secondary Development
Core selling point module:
- Military-grade sports performance
- The 12 joints are fully designed for freedom, supporting difficult movements such as running, climbing, rear-air flipping, etc.
- 9-axis IMU gyroscope + dynamic pace algorithms for recovery from fall and adaptation to complex terrain
- 1 mm STM32 real-time motion control, response delay < 5ms
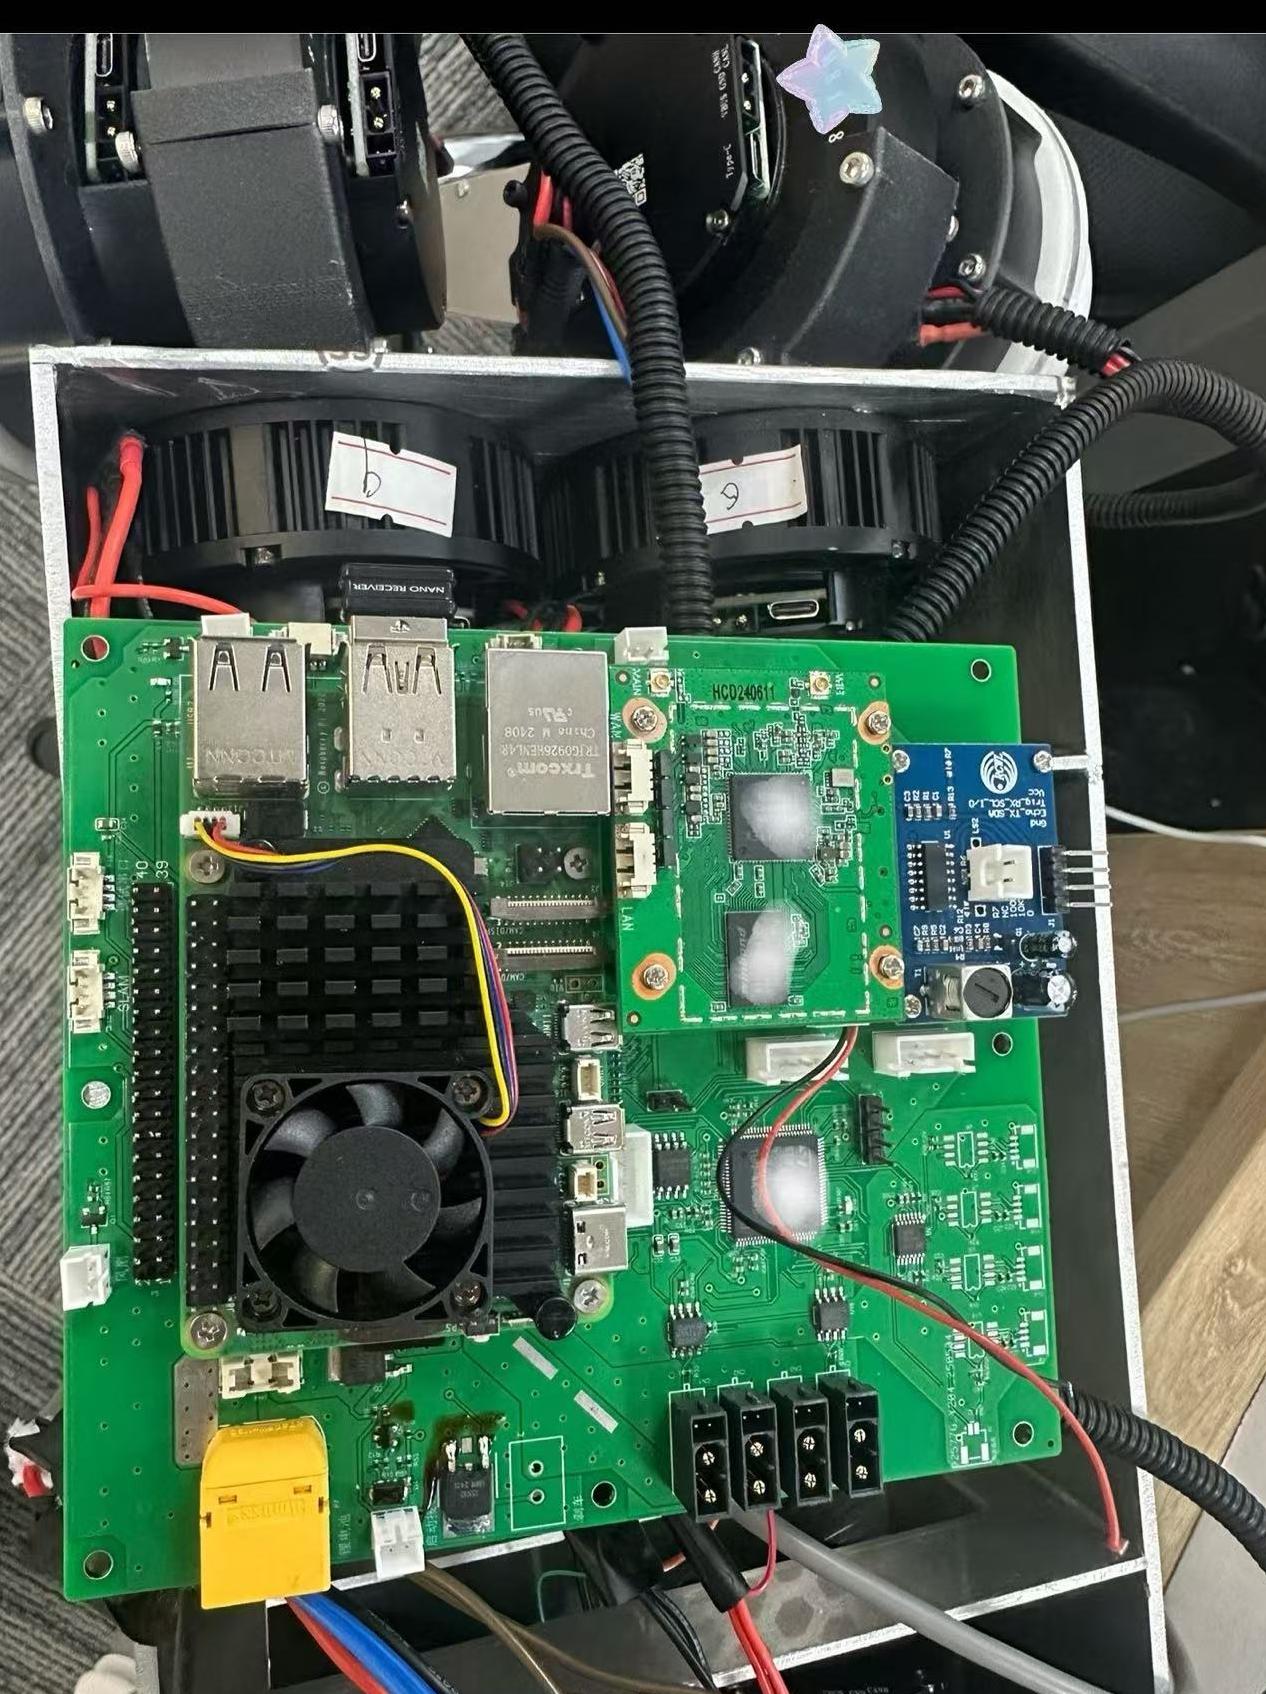
- Dual-brain collaboration architecture
▶ Berry pie master: responsible for visual navigation (optional AI camera), ROS communications and advanced task control
▶ STM32 co-processor: integration of PID control and sensors to ensure motor stability
- Developer-friendly ecosystem
- Provides complete Arduino/C++ SDK and Python API documents
- Support for the Gazebo simulation preview, open SLAM construction interface
- Modular structure design, rapid replacement of wheelers/cells/sensors
- Multi-scenario solution
- Education scientific research: teaching platform/control algorithm validation for robotics
- Industrial inspection: replacing manual entry into high-risk environments
- Smart Accompaniment: Supporting emotional interaction and self-learning
Technical parameter overview:
Resuscitation: 4 hours (6000 mAh Quick Battery)
▸ Load: 5kg (extensible arm module)
• Communications: WiFi6/4G two-module transmission
• Development interface: Type-C debugger + JTAG burner